Flexiv Rizon 4S#
FlexivRizon4SCfg integrates Flexiv’s seven-axis Rizon 4S arm with its bare
flange, original meshes and materials. The catalog ID is FlexivRizon4S.
The preset has one arm control part, containing joint1 through joint7;
it does not attach a gripper or declare an eef control part.
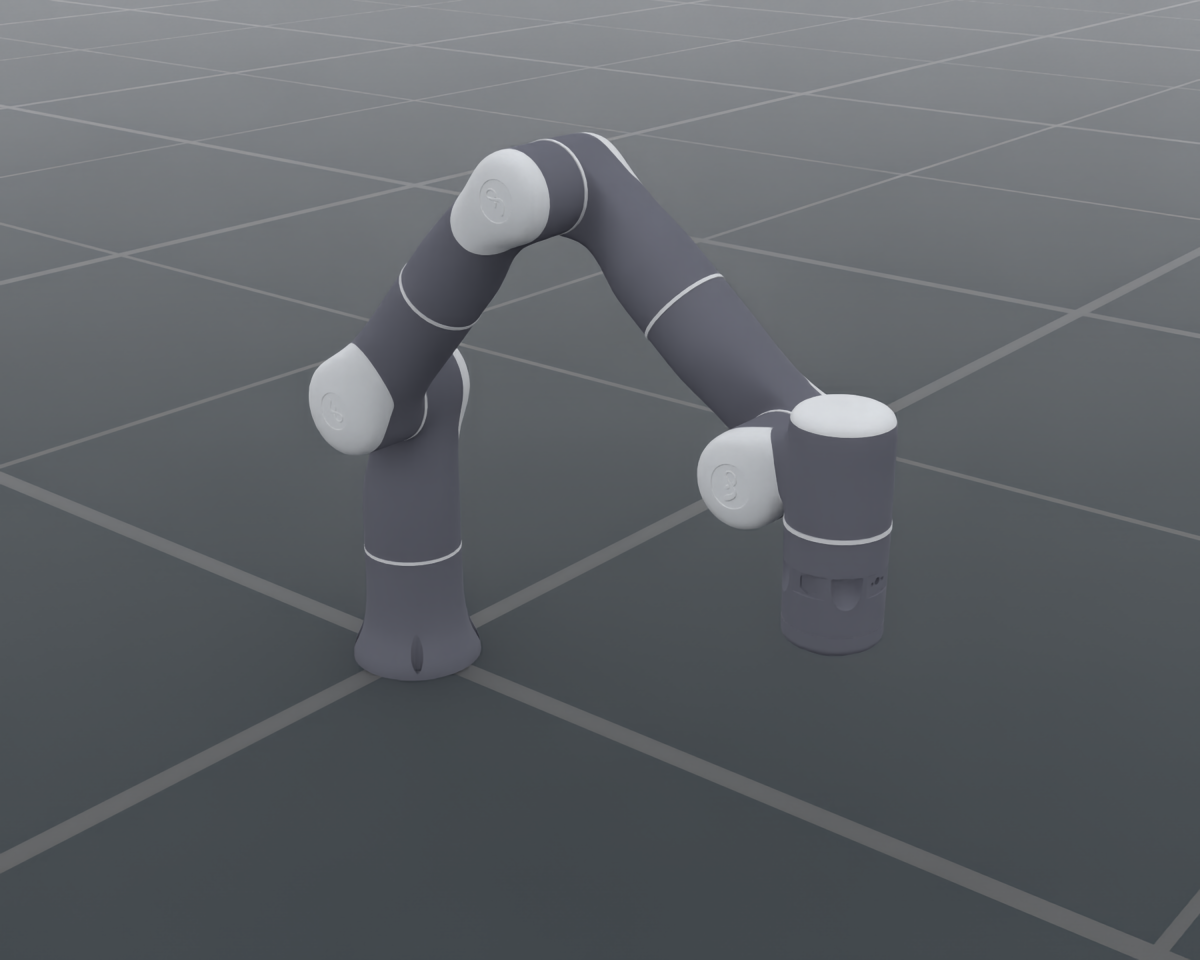
The image uses the catalog defaults and native OfflineRT with the same default lighting/render settings as the other robot resource pages. Camera and renderer settings are recorded in the render manifest.
Usage#
from embodichain.lab.sim import SimulationManager, SimulationManagerCfg
from embodichain_robots import FlexivRizon4SCfg

sim = SimulationManager(SimulationManagerCfg(headless=True))
try:
    cfg = FlexivRizon4SCfg.from_dict({})
    robot = sim.add_robot(cfg=cfg)
    sim.prepare()
    sim.update(step=1)
finally:
    sim.destroy(exit_process=False)
SimulationManager.flush_cleanup_queue()
The shared catalog also accepts resolve_robot_cfg("FlexivRizon4S"), or
class_type: FlexivRizon4S in a robot configuration mapping. Discover and
preview it with:
embodichain list-robot
embodichain data list --category robot
embodichain data download --name FlexivRizon4S
embodichain preview-robot --robot FlexivRizon4S --renderer rt
embodichain preview-robot --robot FlexivRizon4S --headless --renderer no-render --max-steps 300
Assets and kinematic frames#
The approximately 0.8 MB Apache-2.0 asset archive is hosted in the
EmbodiChain Hugging Face dataset.
get_data_path("FlexivRizon4S/rizon4s.urdf") uses the standard FlexivRizon4S
data wrapper to download, checksum and extract it under the shared dataset lock
into the revision-specific FlexivRizon4S_v1 cache. The configured
EMBODICHAIN_DOWNLOAD_PREFIX is tried first, with the official Hugging Face
dataset as a fallback. A network connection is needed for the initial download;
subsequent loads reuse the cache. ROS and Xacro processing are not required.
Catalog listing does not construct the robot or download its assets.
The archive contains the expanded URDF, visual/collision meshes and MTLs,
original parameter/Xacro files, the drive-reference USD layers, LICENSE,
NOTICE and a SHA256 provenance manifest. Expansion changes only mesh paths
to relative paths; joint/link names, transforms and numerical inertial values
remain those of the pinned official description. A derived triangular copy of
the visual joint-ring mesh supports native ray tracing, which skips the source
mesh’s polygon faces. The original OBJ remains in the archive; vertex positions,
UVs, material assignments and collision meshes are unchanged.
Both simulation and build_pk_serial_chain() use the same selected URDF.
An explicit URDF fpath override replaces that source for both consumers.
The chain and the default PytorchSolverCfg run from base_link to flange.
The TCP is identity, so FK returns the bare flange pose. IK targets that same
frame. The general numerical solver accommodates this arm’s offset joint
geometry without assuming Franka or spherical-wrist dimensions.
The initial joint positions are the official ready pose, in source order:
[0, -0.69813, 0, 1.570796, 0, 0.69813, 0] radians.
Published dynamics and simulation drives#
Link masses, centers of mass, complete inertia tensors, position limits and speed limits are preserved from the official URDF. No automatic mass scaling or inertia recomputation is applied. For example, the base mass is 3.788 kg, link 1 is 3.596 kg and link 7 is 1.403 kg in that public model.
These are public simulation parameters. Flexiv’s RDK documentation
states that public URDF dynamics parameters are blurred. Precise robot dynamics
require the flexiv::rdk::Model API on a connected robot. Likewise, the published
Isaac Sim drive gains below do not specify the real controller’s factory gains.
The preset uses the force-drive stiffness and armature from Flexiv’s official
Isaac Sim asset. USD angular stiffness/damping are per degree; multiplying by
180/pi gives the per-radian values consumed by EmbodiChain. Armature remains
in kg·m². The official damping reference is 80 / 70 / 15 N·m·s/rad for
joints 1–2 / 3–4 / 5–7. The preset multiplies that damping by three to suppress
repeated rebound during reachable native IK dragging on the Default backend.
This damping adjustment is simulation tuning, not a manufacturer controller gain.
Joints |
Stiffness (N·m/rad) |
Damping (N·m·s/rad) |
Effort limit (N·m) |
Armature (kg·m²) |
Speed limit (rad/s) |
|---|---|---|---|---|---|
1–2 |
4000 |
240 |
123 |
3.169792 |
2.0944 |
3–4 |
5000 |
210 |
64 |
1.375488 |
2.4435 |
5–7 |
1500 |
45 |
39 |
0.134325 |
4.8869 |
The regression exercises a reachable 8 cm Cartesian arc over 250 ms with the native DexSim IK solver and a 10 ms physics step. Increased damping reduces rebound with some additional tracking lag; it does not resolve IK solution jumps at joint limits or unreachable targets.
Passive joint friction is zero as authored in the official simulation asset.
The fixed base, disabled self-collision and Default-backend root iteration
counts (32 position, 16 velocity) also follow that asset. Newton ignores the
root iteration counts; enforcement of drive/limit fields depends on its
selected solver, as described by JointDrivePropertiesCfg.
As with other robot configurations, joint_drive_props, root_props,
attrs and per-link link_attrs can override these simulation defaults.
For example, tune the shoulder drive without replacing its torque limits:
cfg = FlexivRizon4SCfg.from_dict(
    {"joint_drive_props": {"stiffness": {"joint[1-2]": 3000.0}}}
)
Pinned sources#
Flexiv description, jazzy-v3.1:
config/Rizon4s,meshes/Rizon4s, and the official Xacro macros.Flexiv Isaac Sim workspace:
physics.usdasupplies gains/effort, andphysx.usdasupplies armature, friction and root iteration counts.Archive SHA256:
850c9531a19d103b15c9609f60a6d594dbde602032c8fbb34b73c83fc4ecabf3.