UR Family (UR3 / UR5 / UR10 + e variants)#
URRobotCfg covers six Universal Robots manipulators in one configuration class:
ur3, ur3e, ur5, ur5e, ur10, and ur10e. The images below show the exact
variants currently documented in EmbodiChain: the compact UR3 pair, the mid-reach
UR5 pair, and the long-reach UR10 pair, using their versioned asset materials.
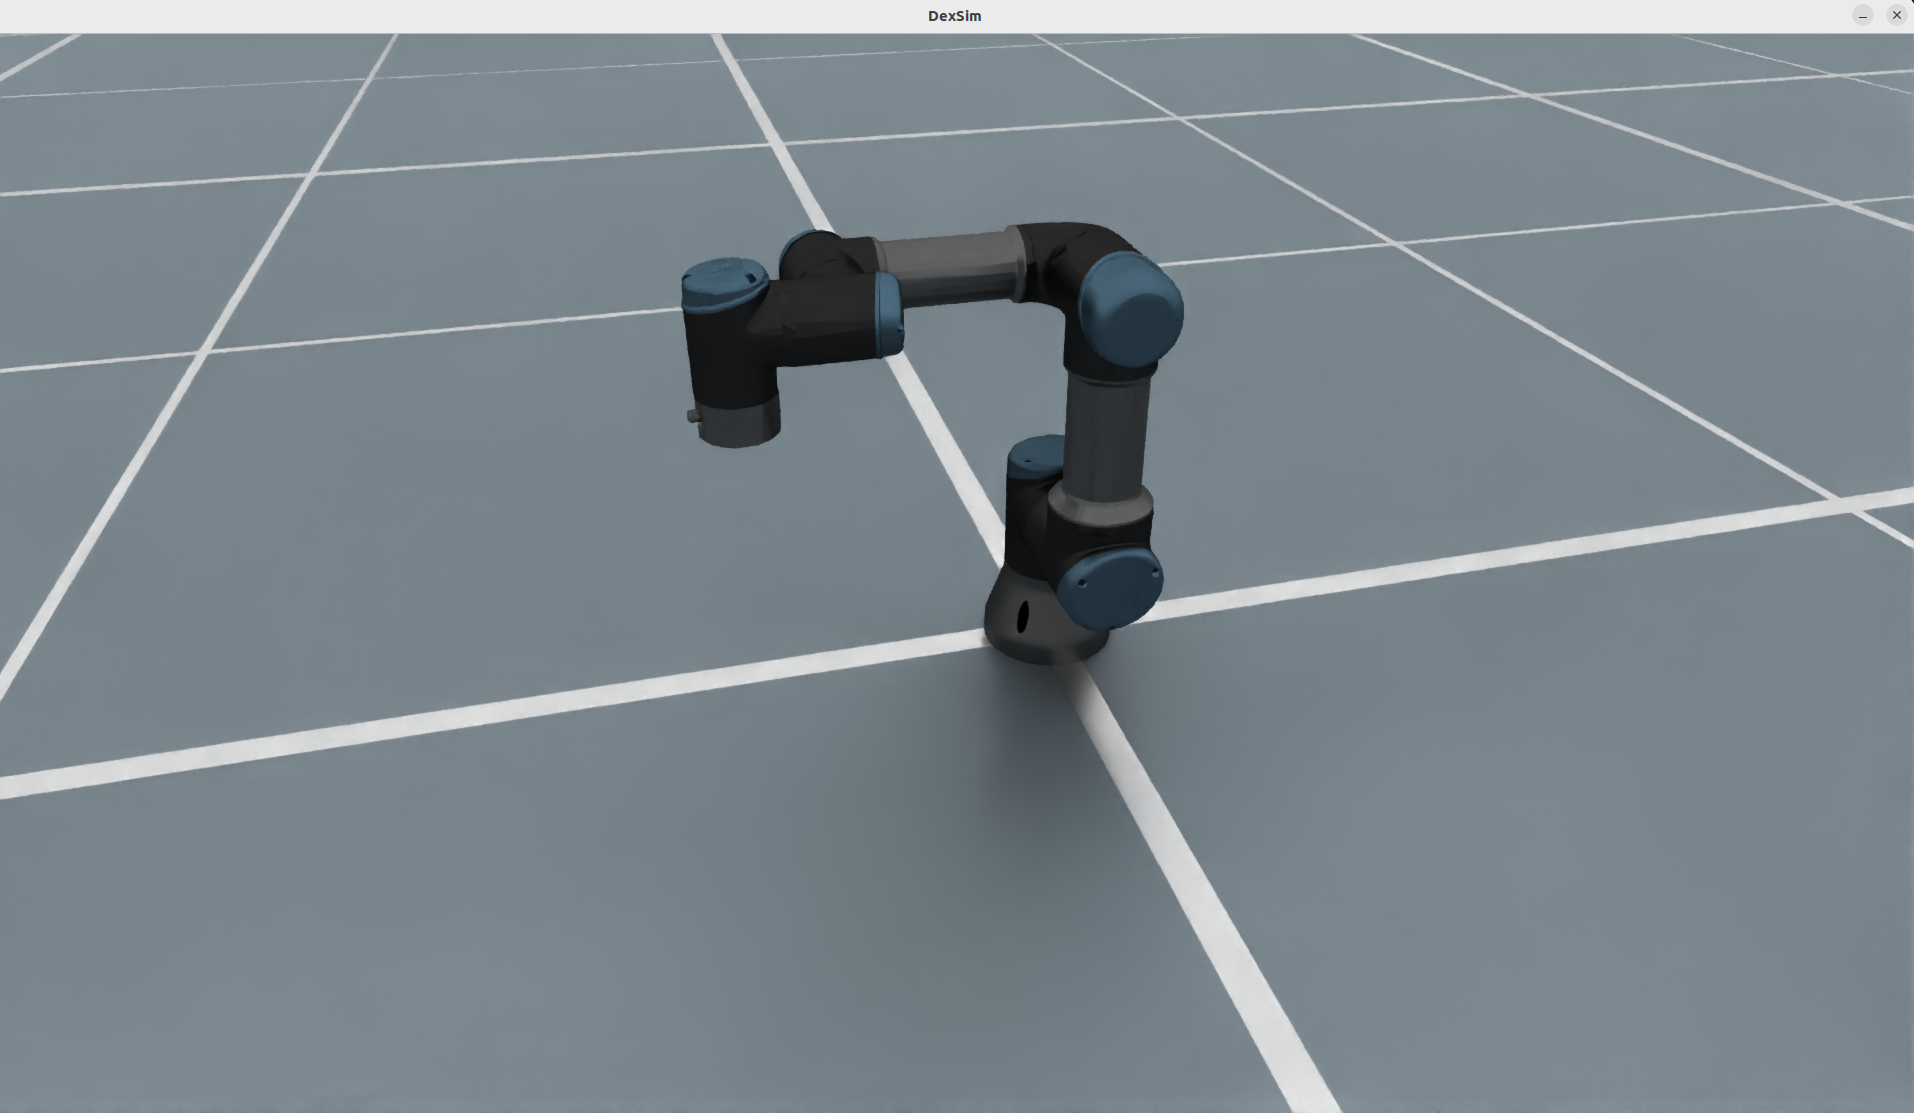
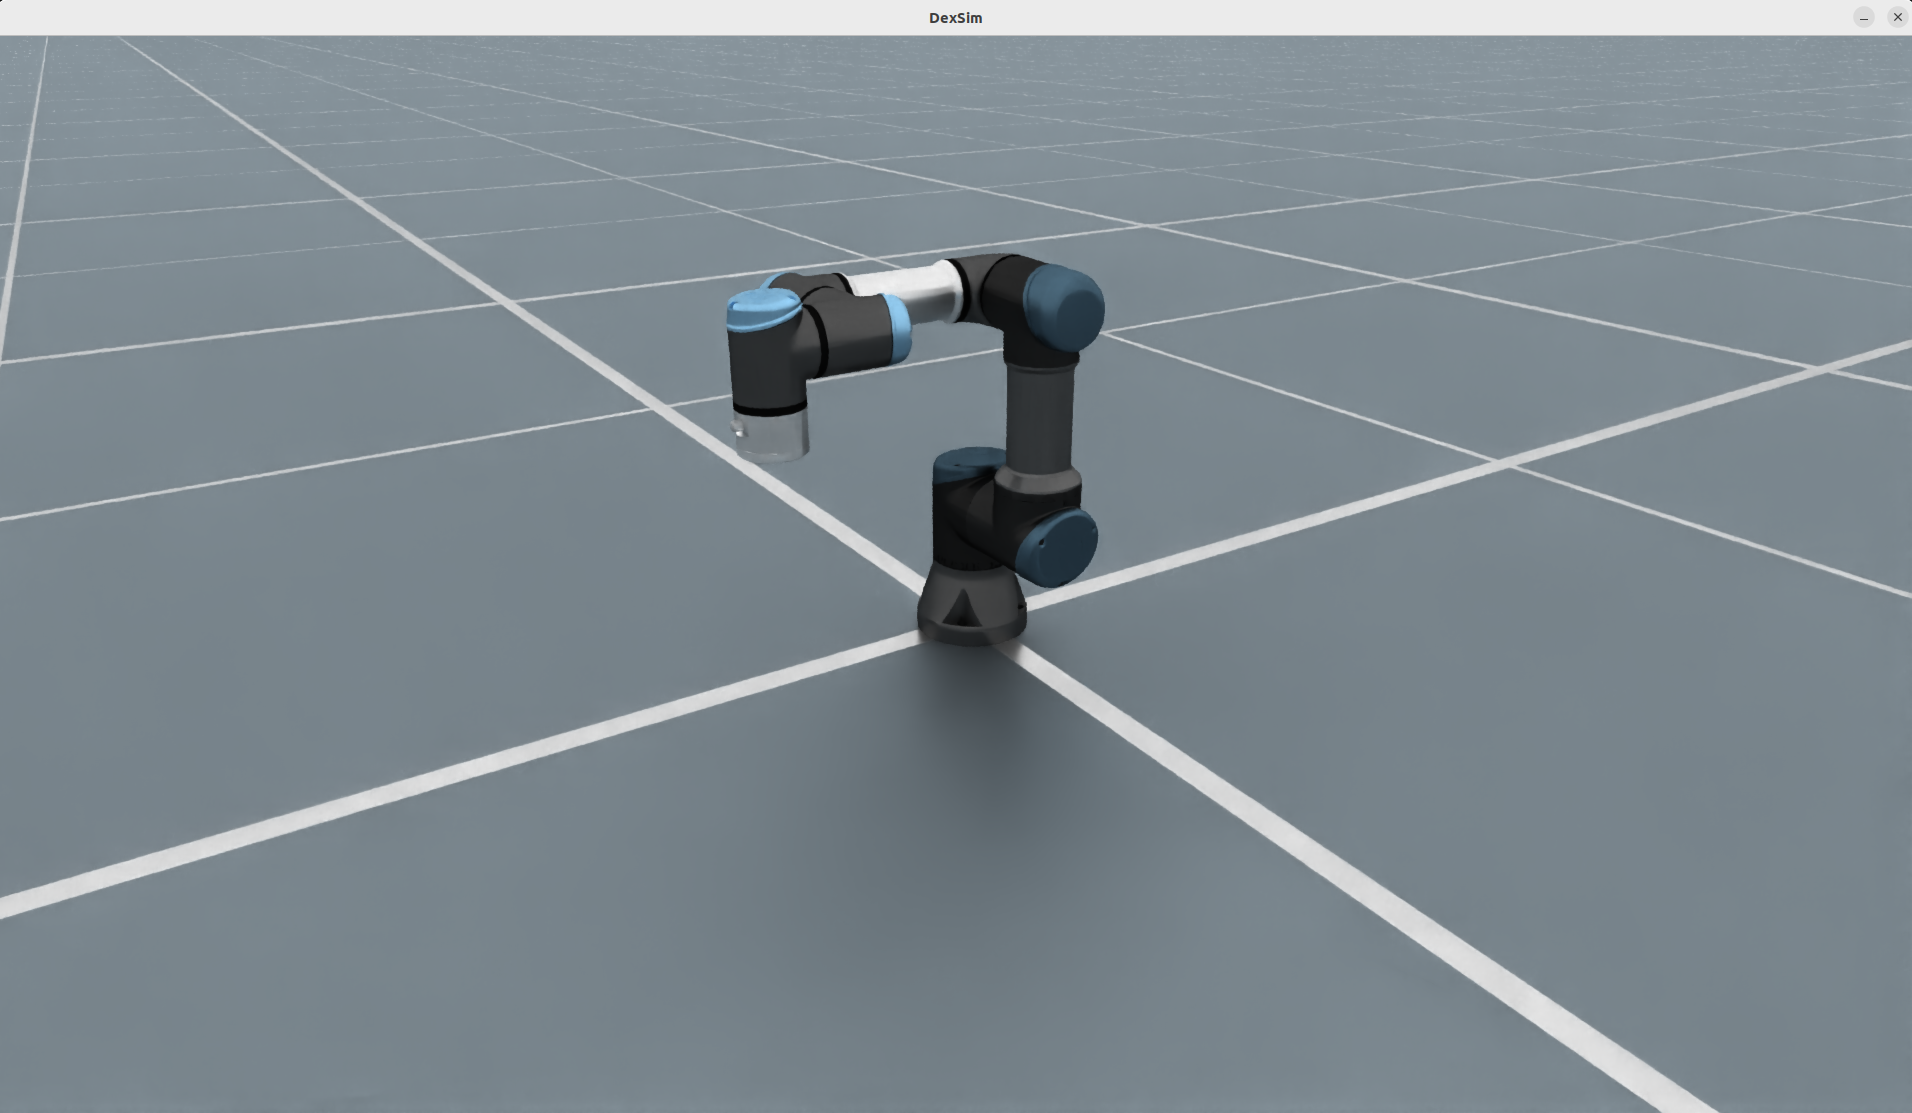
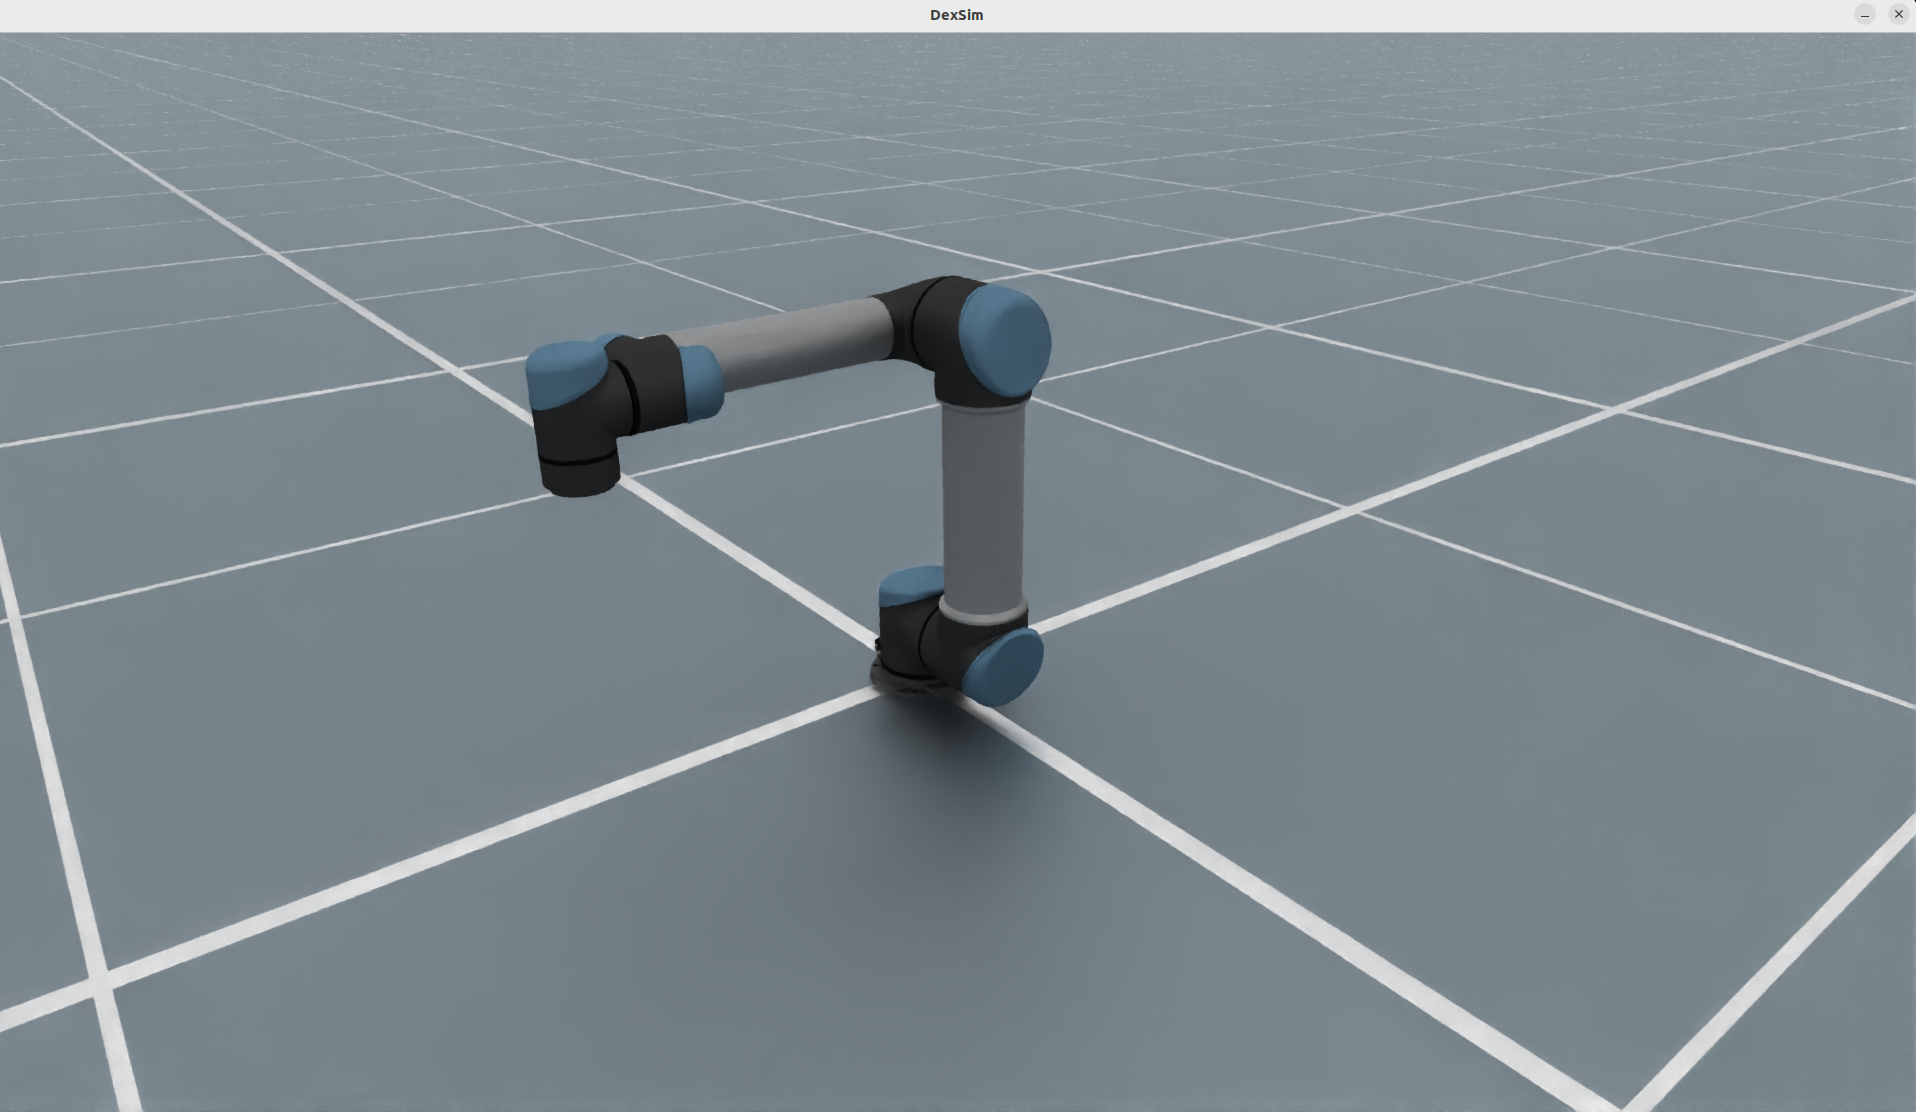
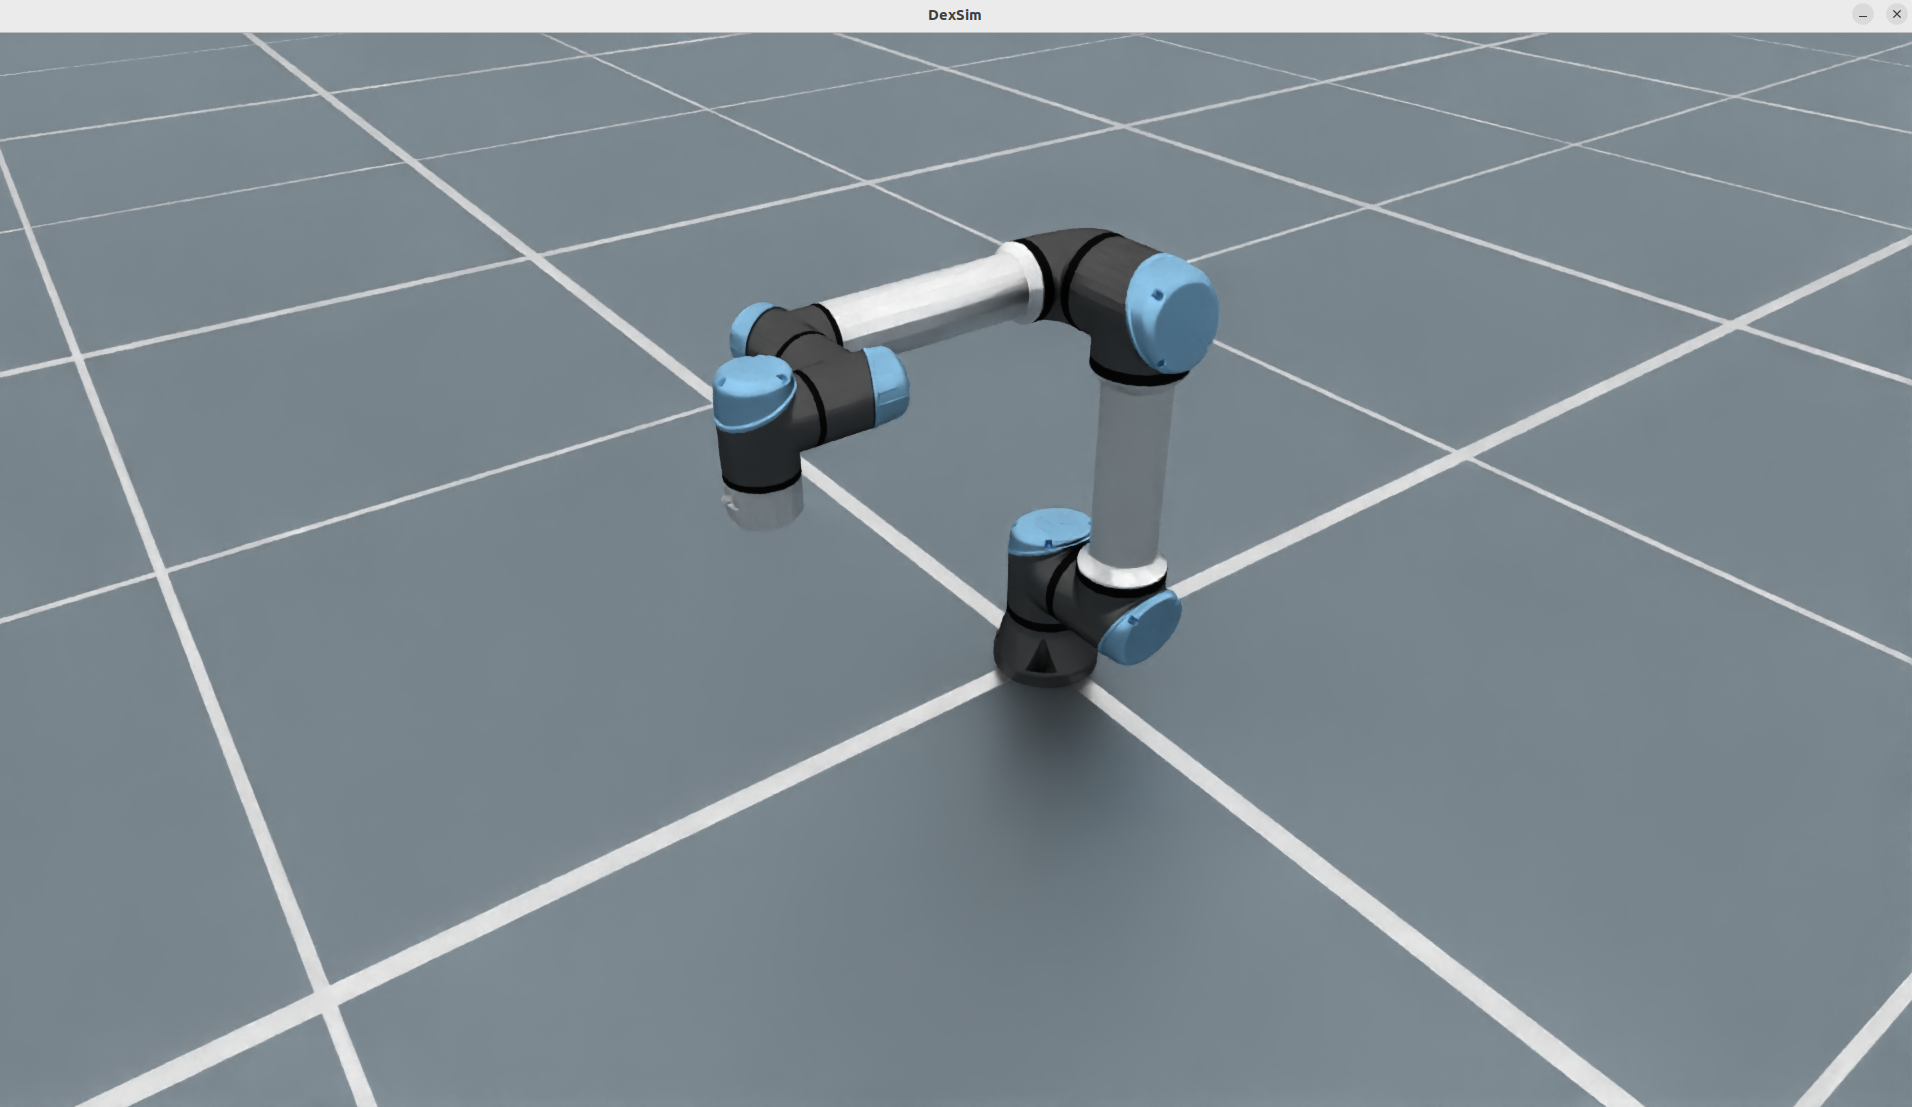
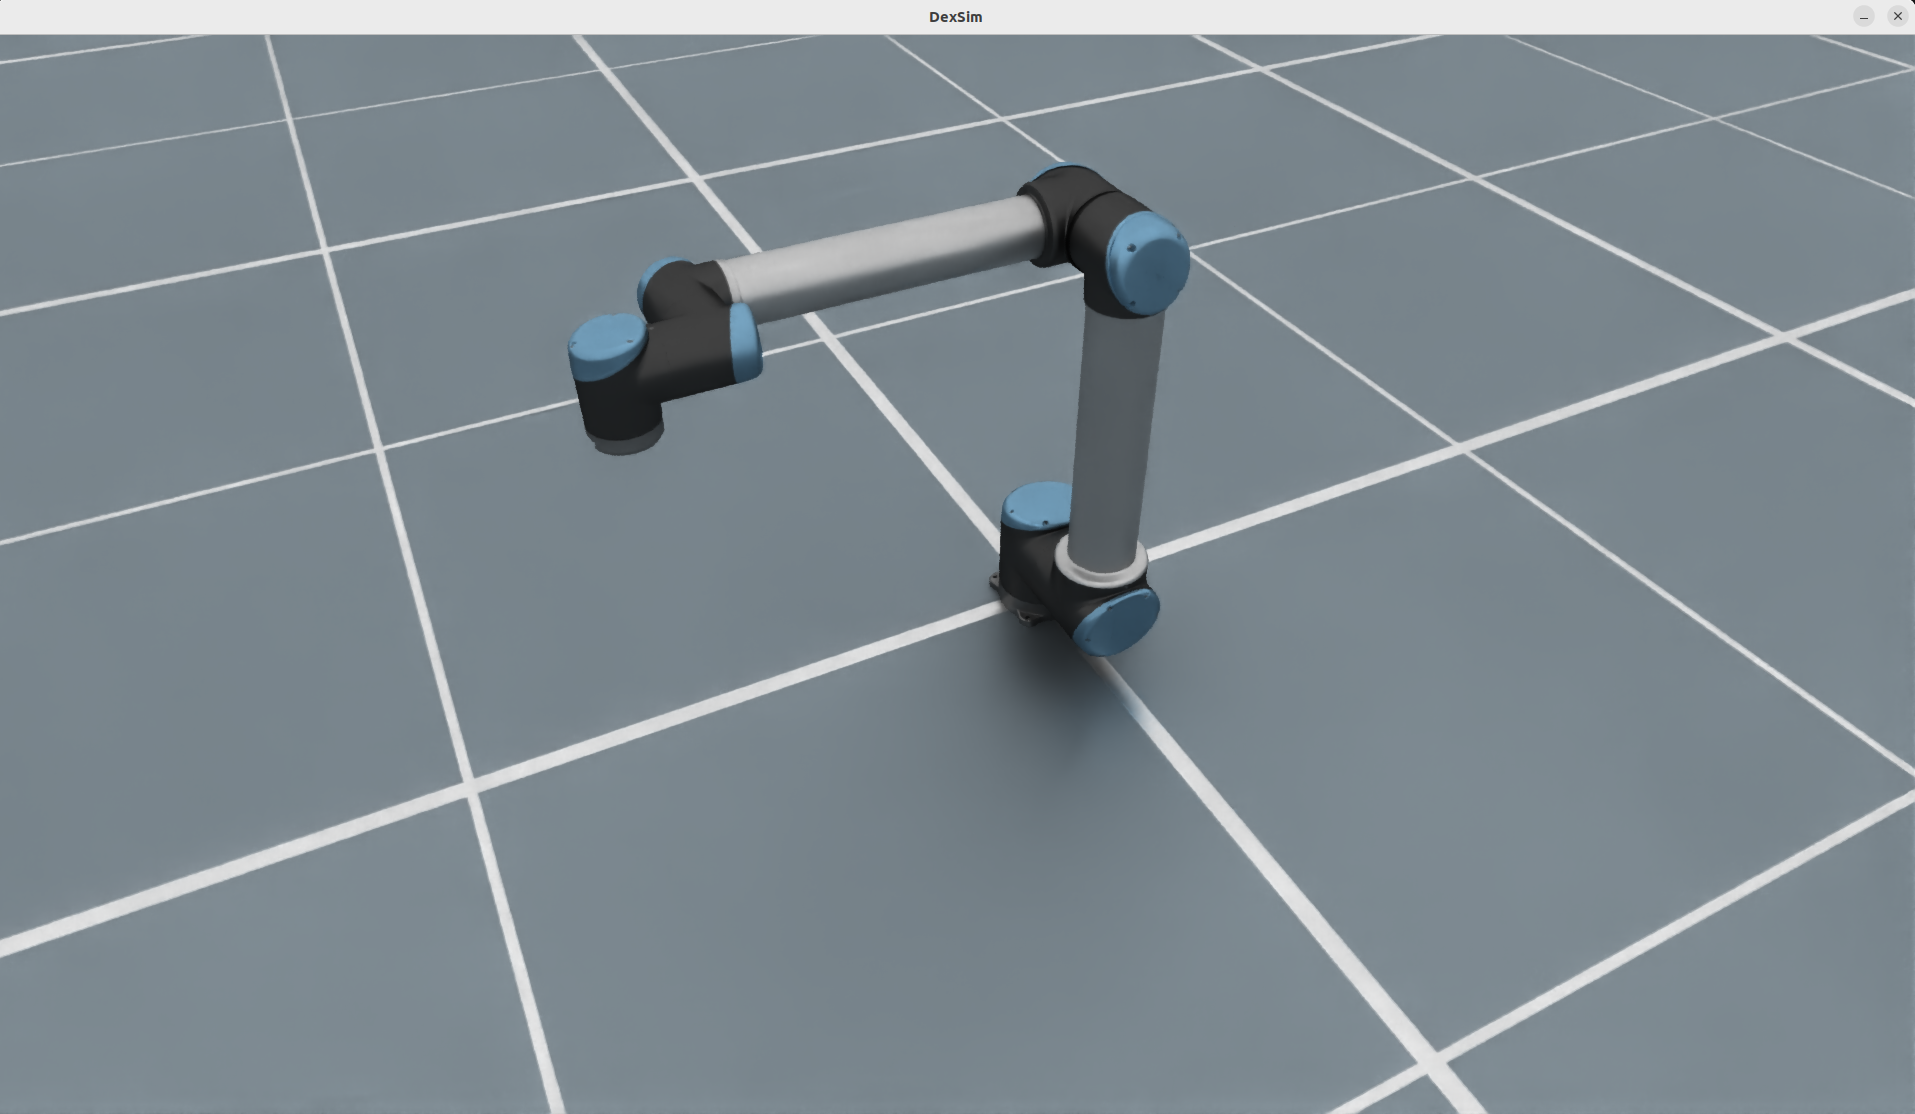
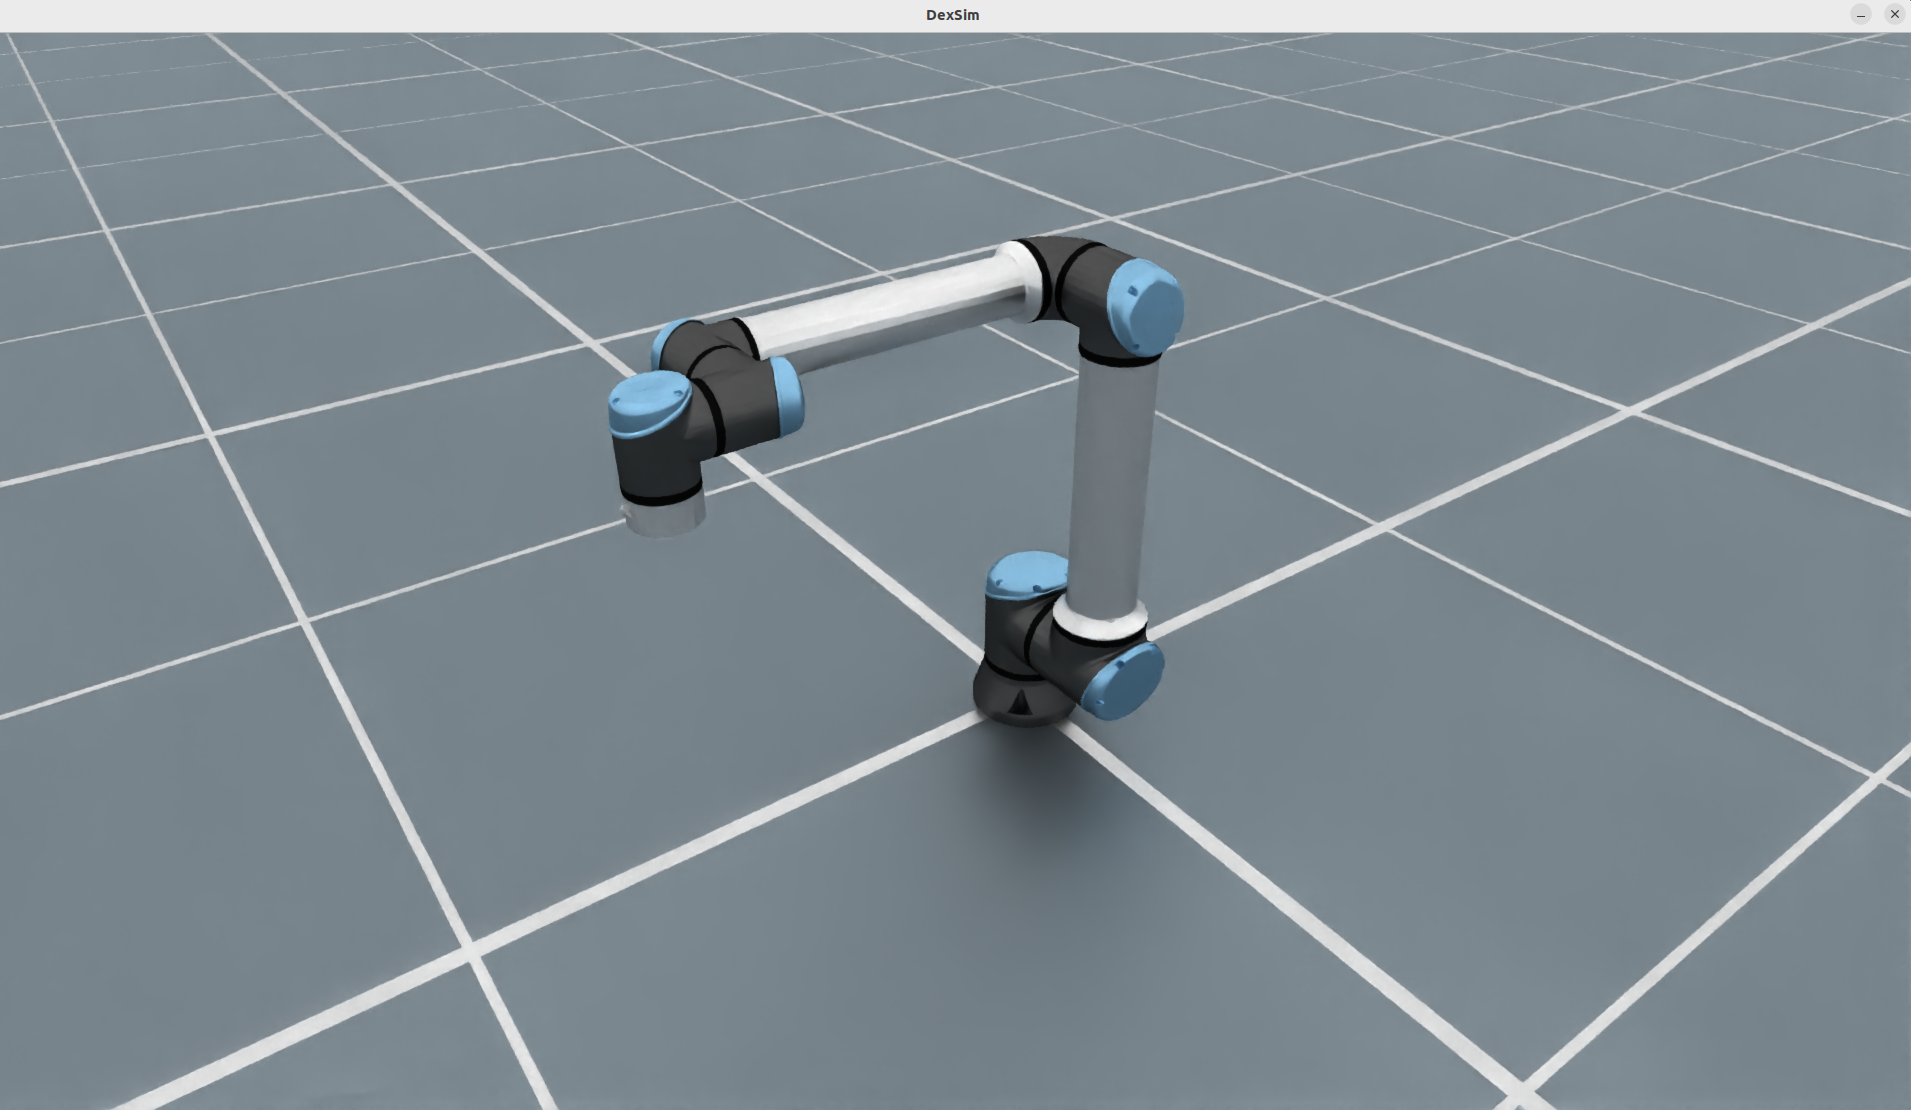
Images use RenderCfg(renderer="rt") (OfflineRT), default lighting and a common
display pose. The V4 asset bundle corrects the UR3/UR3e material colors while
preserving geometry and kinematics. Camera and rendering settings are recorded
in the render manifest.
Key Features#
One config, six UR variants selected through
robot_type.Image-matched family lineup from the shortest-reach UR3 pair to the longest-reach UR10 pair.
Distinct link and joint materials with silver links, grey housings and blue joint covers.
Analytic UR inverse kinematics through
URSolverCfgand the Warp-based UR solver path.Simulation-ready defaults for URDF selection, control parts, drive properties, and rigid-body attributes.
Visual Differences Across Variants#
UR3 / UR3e are the most compact renders in the set and keep the wrist close to the base.
UR5 / UR5e extend the shoulder-to-wrist span while keeping the same 6-axis arm layout.
UR10 / UR10e show the longest upper-arm and forearm links, matching the largest reach tier in the family.
UR3 / UR3e materials use the corrected V4 palette, removing the legacy darkening of the silver links and blue joint covers.
Usage#
from embodichain.lab.sim import SimulationManager, SimulationManagerCfg
from embodichain_robots import URRobotCfg

sim = SimulationManager(SimulationManagerCfg(headless=True, num_envs=4))
cfg = URRobotCfg.from_dict({"robot_type": "ur5"})
robot = sim.add_robot(cfg=cfg)
Robot Parameters#
Parameter |
Description |
|---|---|
|
UR variant: |
Number of joints |
6 revolute joints plus the fixed |
Control parts |
|
Root / end link |
|
Solver |
|
Drive |
UR3/UR3e about 56 N.m, UR5/UR5e about 150 N.m, UR10/UR10e about 330 N.m |
Note: The
ur5URDF uses lowercase joint names (joint1tojoint6), while the other variants useJoint1toJoint6.URRobotCfg._build_defaultsselects the correct naming scheme automatically.
Variants at a Glance#
|
Preview |
URDF |
Reach (m) |
Payload (kg) |
|---|---|---|---|---|
|
Compact classic render |
|
~0.5 |
3 |
|
Compact e-series render |
|
~0.5 |
3 |
|
Mid-size classic render |
|
~0.85 |
5 |
|
Mid-size e-series render |
|
~0.85 |
5 |
|
Long-reach classic render |
|
~1.3 |
10 |
|
Long-reach e-series render |
|
~1.3 |
10 |
See Also#
:doc:
/guides/add_robot- Adding a new robot (quick reference):doc:
/overview/sim/motion/solvers/index- IK solver reference