SO101 Follower#
SO101FollowerCfg configures The Robot Studio’s SO101 follower: a five-axis
arm and one actuated gripper jaw. The canonical catalog ID is SO101Follower.
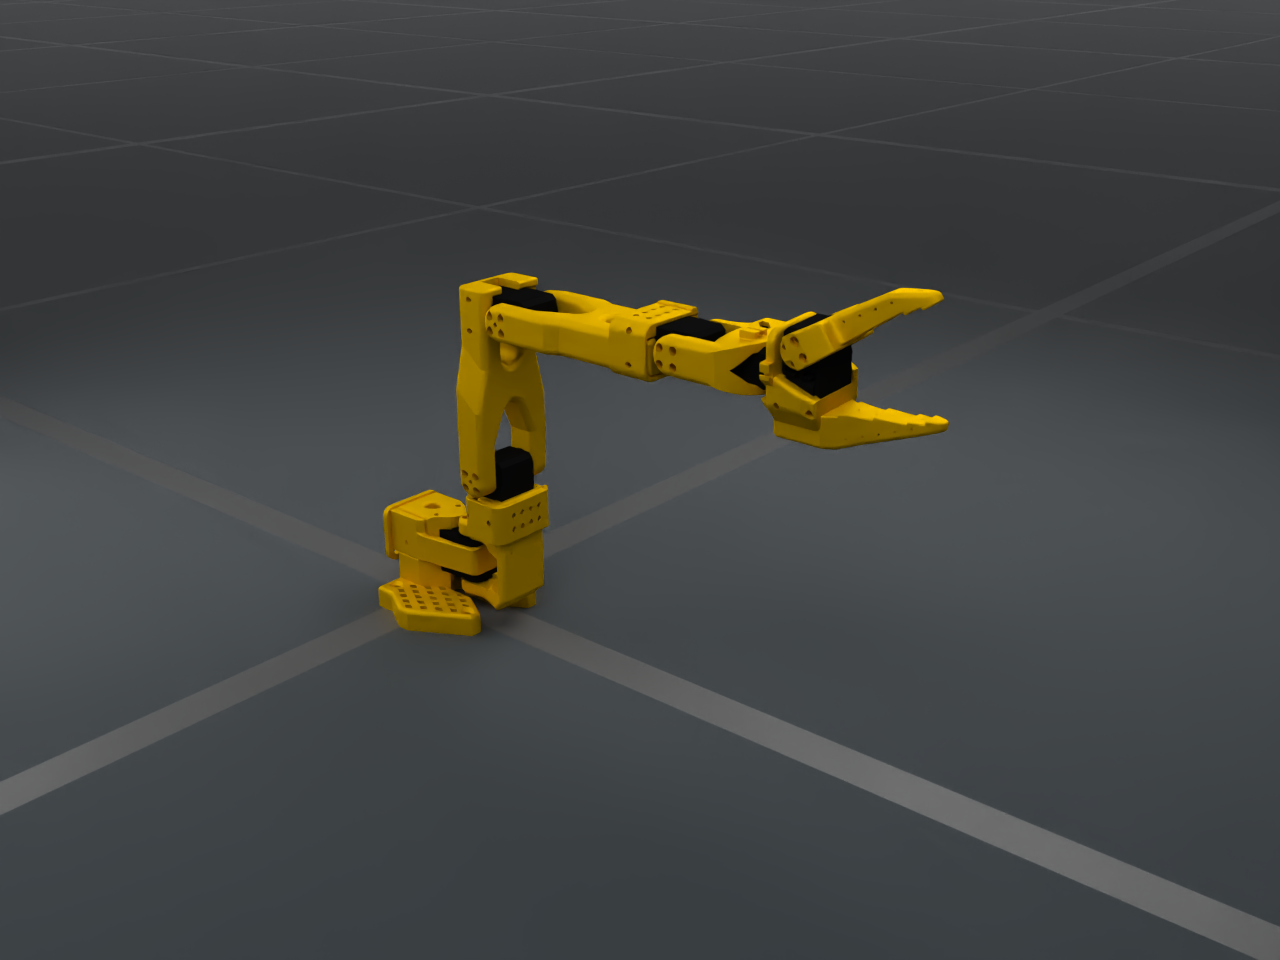
embodichain data download --name SO101FollowerAssets
embodichain preview-robot --robot SO101Follower --renderer fast-rt
For browser joint controls, add --viser. Native DexSim rendering displays the
yellow printed parts and dark STS3215 housings; Viser uses simplified colors.
Usage and control parts#
from embodichain.lab.sim import SimulationManager, SimulationManagerCfg
from embodichain_robots import SO101FollowerCfg

sim = SimulationManager(SimulationManagerCfg(headless=True))
cfg = SO101FollowerCfg.from_dict({})
robot = sim.add_robot(cfg)
sim.prepare()

arm_ids = robot.get_joint_ids("arm")
gripper_ids = robot.get_joint_ids("eef")
Control part |
Independent joints |
|---|---|
|
|
|
|
There are six independent control DOFs and no mimic followers. The base is
fixed; self-collision is disabled by default. Initial joint positions are zero
in the source’s new calibration convention. The gripper is a revolute
joint in radians; LeRobot’s normalized 0..100 gripper command is not a
simulation joint position and requires an explicit mapping.
Kinematics and frames#
The simulation and build_pk_serial_chain() use the same official
so101_new_calib.urdf component, retaining all asset-defined names.
Chain |
Root |
End |
DOFs |
|---|---|---|---|
|
|
|
5 |
|
|
|
1 |
The arm ends at the source’s fixed gripper frame, including its authored TCP
translation and rotation. The jaw chain is local to the gripper body.
PytorchSolverCfg supplies arm FK and DLS position-only IK: five arm joints
cannot satisfy every arbitrary 6D target pose. The jaw has no IK solver.
Dynamics and provenance#
The preset pins The Robot Studio’s SO-ARM100 repository
at commit a758567c3978dfeefe282ede0500085a48fe8f78. Its unmodified URDF,
thirteen mesh files, motor-reference XML, README and Apache-2.0 license are
cached by SO101FollowerAssets. Every file has a pinned SHA256. The first
construction requires network access; later constructions verify and reuse
the revision-specific cache. EMBODICHAIN_DATA_ROOT selects its root.
The seven physical links retain their source CAD mass, COM and full inertia tensor; the preset does not scale or replace them. Their total mass is approximately 0.732006 kg, excluding the negligible dummy TCP link. The source’s fixed dummy TCP link has zero inertia; DexSim applies its normal small-inertia fallback to that frame while retaining the seven physical links.
Motor parameters follow the official
joints_properties.xml,
which adapts STS3215 simulation properties from Open Duck Mini. They are
simulation references, not hardware-identified parameters or guaranteed
servo specifications. Actual torque depends on the servo voltage/model.
Joint property |
Default |
Source / interpretation |
|---|---|---|
Drive type |
|
Torque-based position/velocity drive |
Position gain |
|
XML position actuator |
Velocity damping |
|
XML joint damping, represented as drive damping for zero-velocity position holds |
Friction |
|
XML |
Armature |
|
XML joint-space artificial inertia |
Maximum effort |
|
XML actuator |
Maximum velocity |
|
Published URDF limit |
Position limits |
Source URDF |
Retains the pinned model’s calibration offsets |
Standard overrides remain available:
cfg = SO101FollowerCfg.from_dict(
    {"joint_drive_props": {"max_effort": 1.6, "stiffness": 20.0}}
)
Choose hardware-specific limits separately when connecting a real arm. The upstream reference’s passive damping and this drive’s damping are equivalent for zero-velocity position holds; nonzero velocity-target control has different semantics. The preset does not simulate the optional upstream backlash joints.