Unitree Go1#
UnitreeGo1Cfg configures the bundled 12-joint Unitree Go1 quadruped,
including its floating base, standing pose and simulation PD drive defaults.
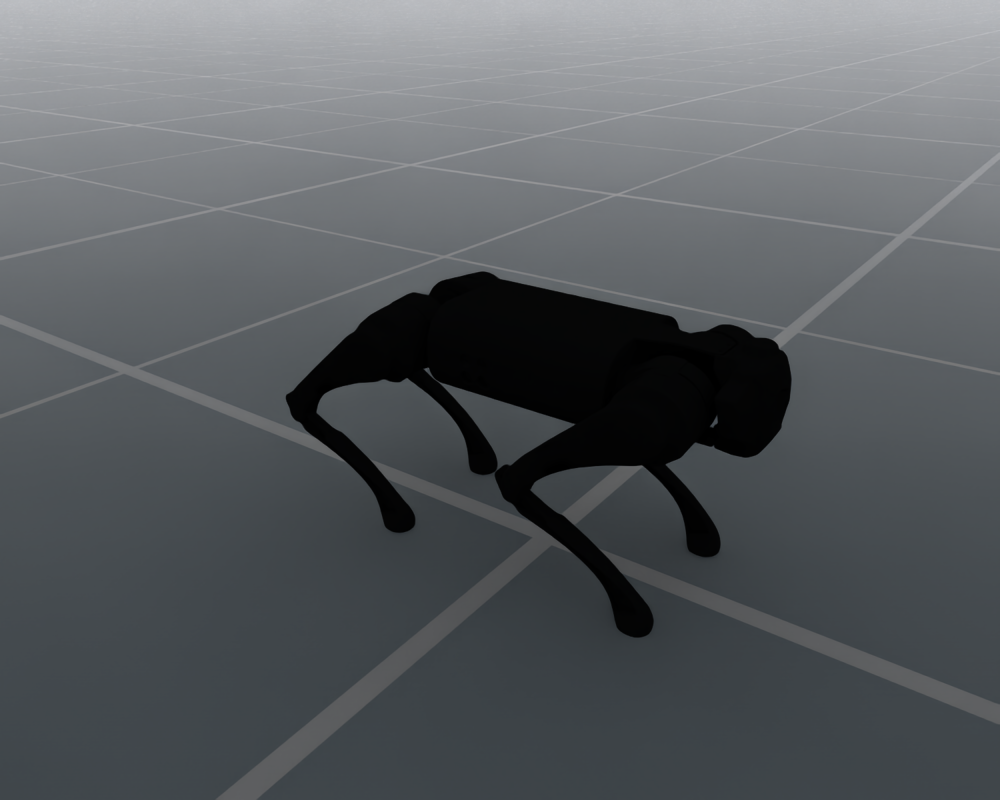
Unitree Go1 in the default joint pose
Usage#
from embodichain.lab.sim import SimulationManager, SimulationManagerCfg
from embodichain_robots import UnitreeGo1Cfg

sim = SimulationManager(SimulationManagerCfg(headless=True, num_envs=1))
cfg = UnitreeGo1Cfg.from_dict({})
robot = sim.add_robot(cfg=cfg)
The catalog ID is also accepted by the shared preview command:
embodichain preview-robot --robot UnitreeGo1
Robot Configuration#
Item |
Default |
|---|---|
Catalog ID / UID |
|
Configuration class |
|
Canonical module |
|
Vendor |
|
Morphology |
|
Arm count |
0 |
Asset |
|
Control parts |
|
Base |
Floating |
Initial root height |
0.278 m |
Physics backends |
Default and Newton |
Limb IK solvers |
None; |
Standard RobotCfg overrides, including joint_drive_props, are accepted
by from_dict. Locomotion tasks preserve these explicit overrides.