DH-Robotics PGC-140-50#
The _M archive is a DexForce-modified PGC-140-50 asset: the historical registry records changes to the connector and fingers. The two assets retain separate IDs and checksums. The unmodified-looking ID does not establish an original-manufacturer URDF release.
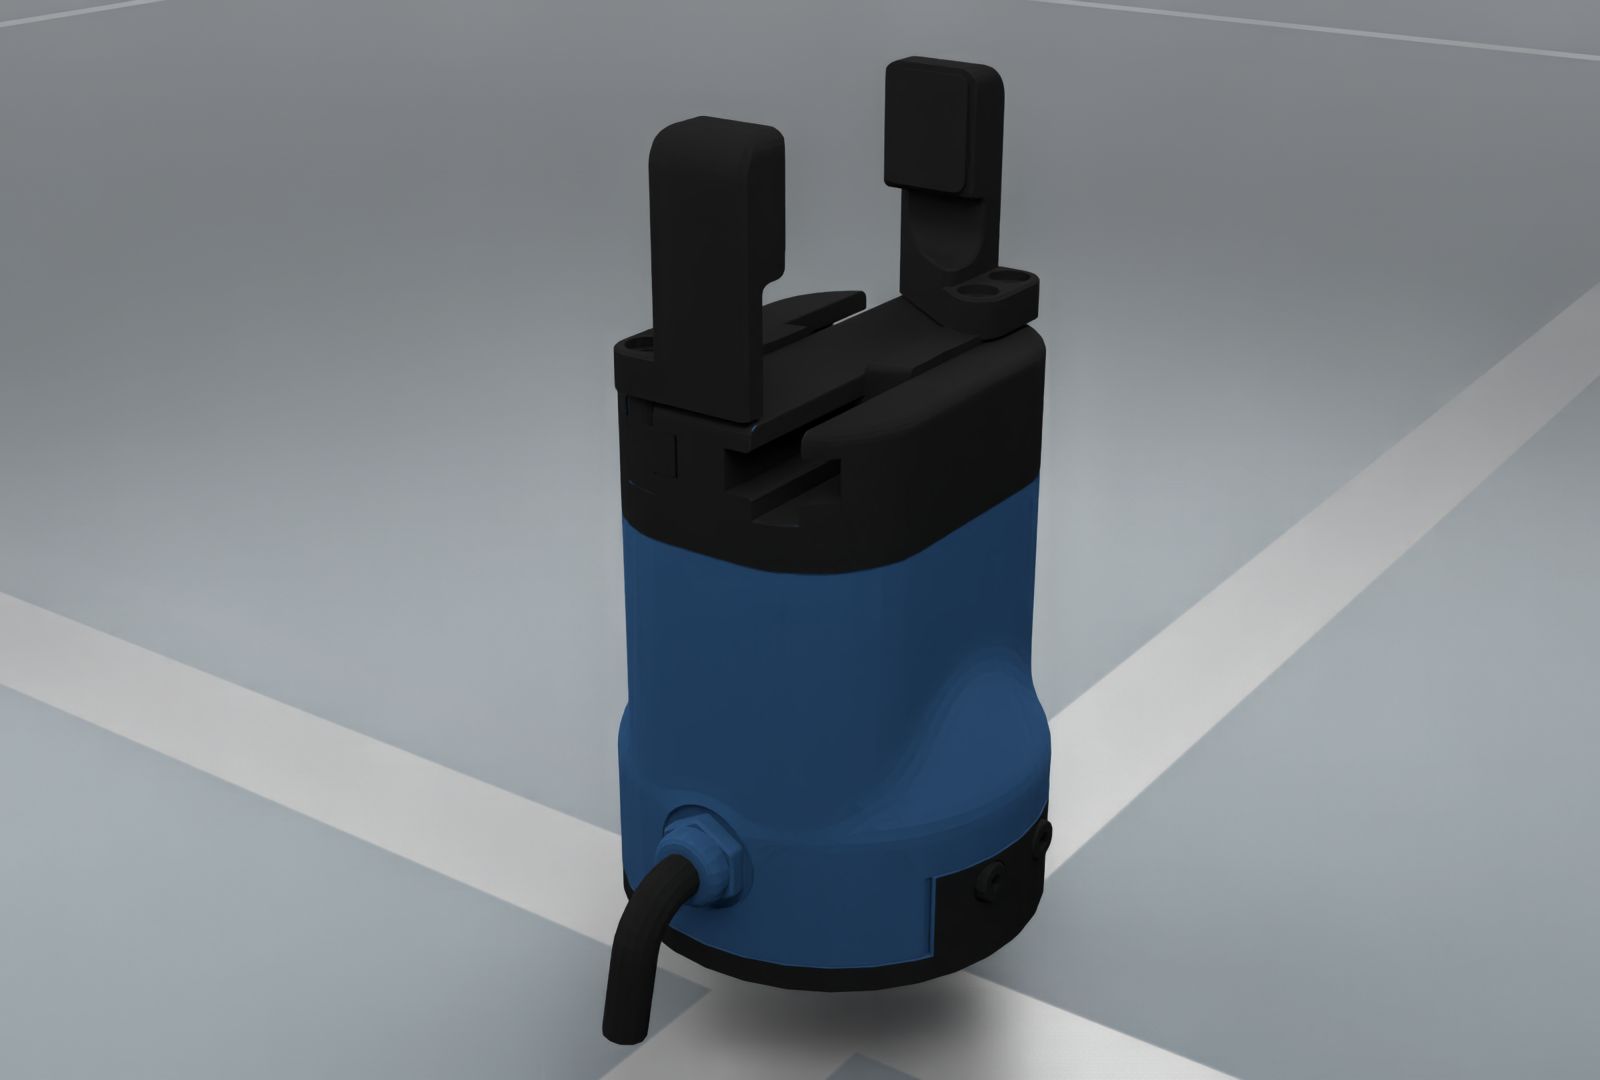
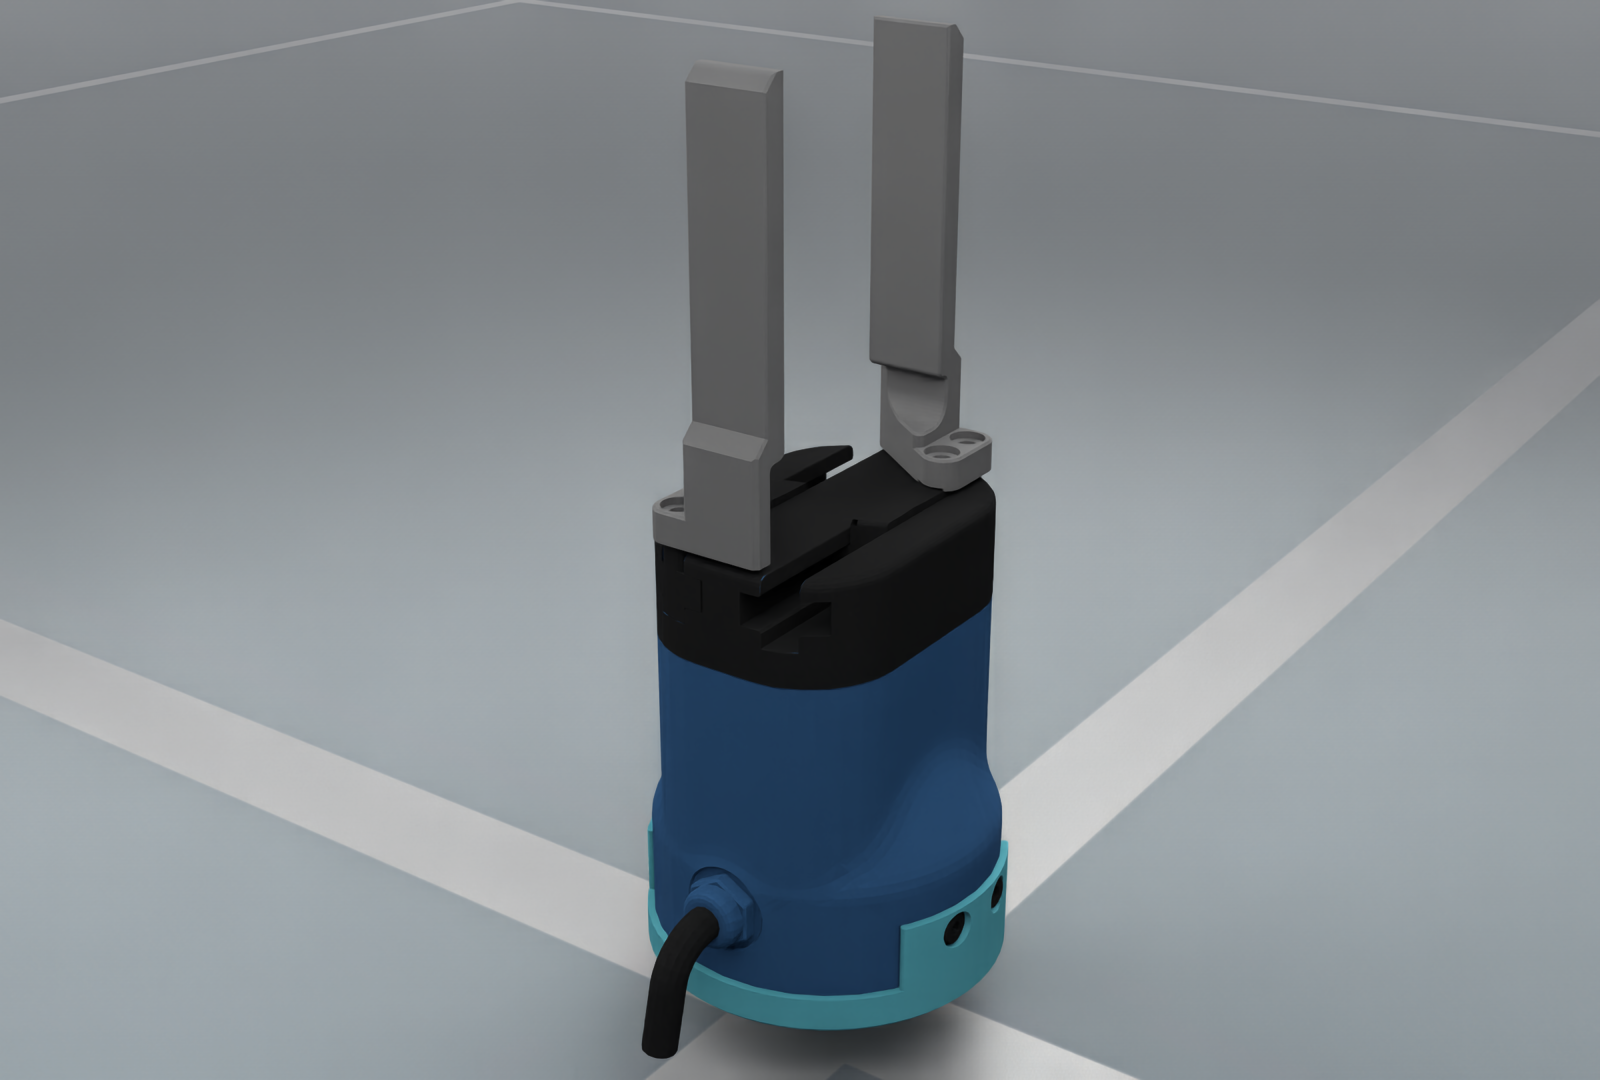
The images use the archive’s visual meshes and authored materials in native OfflineRT. They show a zero-coordinate display pose with a presentation root transform, without stepping physics. Rendering settings and the source URDF checksum are recorded per image. See EEF rendering conventions.
Resolve and preview#
Canonical download-class import:
from embodichain_robots.dh_robotics.pgc_140_50.assets import DH_PGC_140_50, DH_PGC_140_50_M
Use the stable asset reference for normal loading:
from embodichain.data import get_data_path

urdf_path = get_data_path("DH_PGC_140_50/DH_PGC_140_50.urdf")
embodichain data download --name DH_PGC_140_50
embodichain preview-asset --asset_path /absolute/path/to/DH_PGC_140_50.urdf --viser
Pass the resolved absolute urdf_path to preview-asset. Asset listing and
class lookup do not download the archive; resolving its files may download on
first use. The remaining source models in this archive are listed in the image
captions above.
Ownership and provenance#
The download class lives in extensions/embodichain_robots/dh_robotics/pgc_140_50/assets.py and registers through the
existing embodichain.assets catalog with category eef. This asset-only
package does not introduce a standalone robot preset. Host assembly owns the
mounting transform, naming prefix, control-group mapping and task-specific TCP.
The asset provenance record separately records manufacturer affiliation, model matching, asset production, archive distribution, modifications and license status. Missing upstream or license evidence stays explicitly unverified. The Python implementation’s Apache header is not an asset license statement.