FrankaPanda — compatibility and native-hand setup#
FrankaPandaCfg is a compatibility selector for the historical FR3 asset family.
robot_type: panda continues to choose that model; it now constructs its bare
seven-joint arm ending at fr3_link8. New callers use FrankaCfg with
arm_model: fr3 or arm_model: panda.
Mount end effectors with ordinary URDF components, control groups, drive
parameters and solver TCP overrides, as for UR robots. The franka_panda
embodiment explicitly installs the native hand for existing task deployments.
See Franka configuration for arm selection, assembly and migration.
Bare compatibility constructor#
from embodichain_robots import FrankaPandaCfg

cfg = FrankaPandaCfg.from_dict({"robot_type": "panda"})
robot = sim.add_robot(cfg=cfg)
The catalog ID FrankaPanda and YAML class_type: FrankaPanda remain valid.
This constructor exposes arm with seven joints and a flange TCP. Its native
joint names are fr3_joint1 through fr3_joint7; the end link is fr3_link8.
Explicit native-hand assembly#
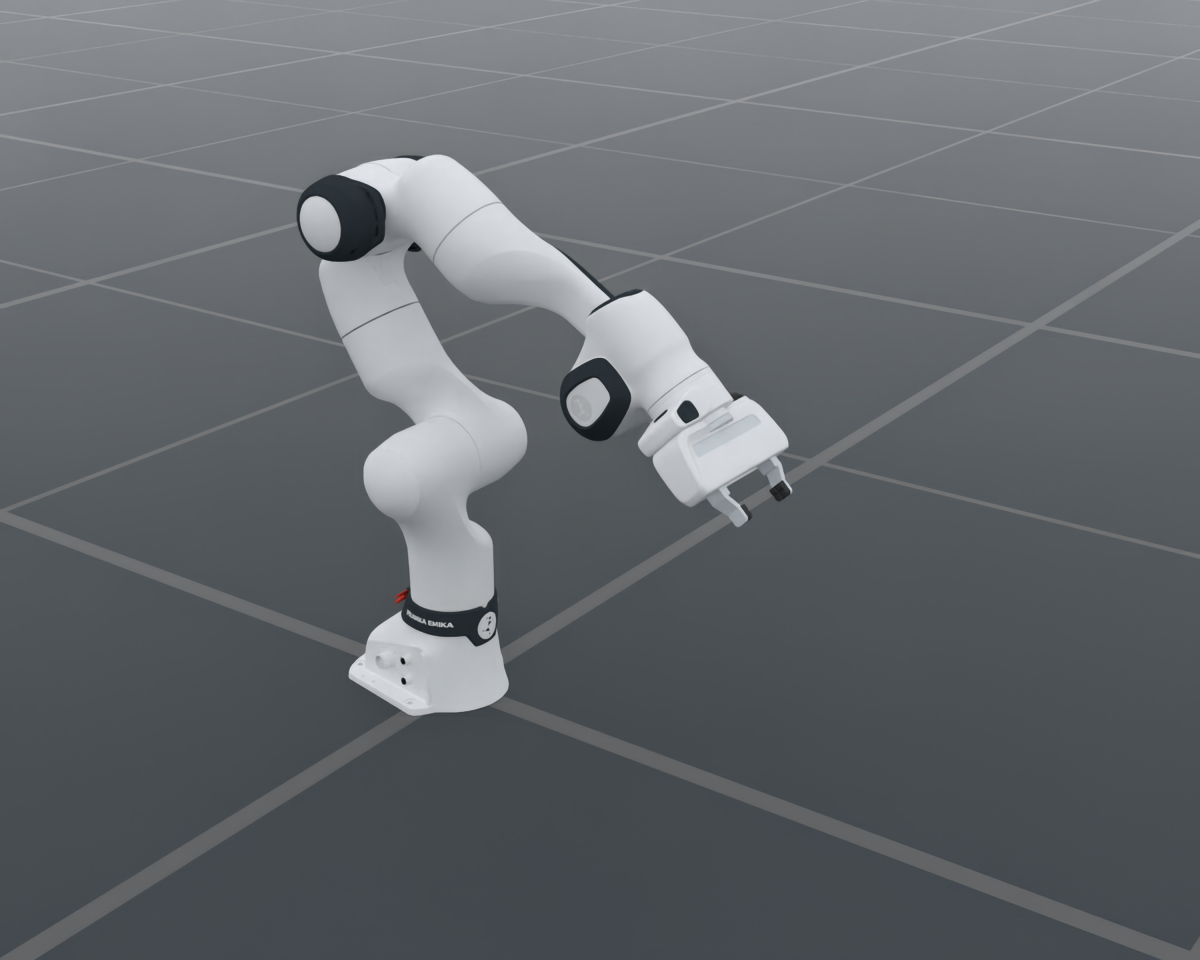
FrankaPanda — native-hand assembly (explicit franka_panda embodiment)
The hand-equipped layout shown here is loaded from the existing embodiment component. It uses the same camera, lighting and arm pose as the Franka bare-arm illustration. The render record includes both source components and their transforms.
The embodiment is a reusable configuration, selected independently of the arm
class. It adds two named finger joints to the seven arm joints; the source
mimic relation leaves one independent finger drive. Its control groups are
arm and eef, and its solver TCP includes the hand mounting rotation and
103.4 mm flange-to-TCP offset.
For standalone construction, load that component through the public catalog:
from embodichain.robot_registry import resolve_robot_cfg
from embodichain.utils.utility import load_config
from embodichain_tasks.configs import get_config_path

fields = load_config(get_config_path("components/embodiments/franka_panda.yaml"))[
    "simulation"
]
cfg = resolve_robot_cfg(fields.pop("class_type"), fields)
robot = sim.add_robot(cfg=cfg)
The Task Program quickstart
uses this explicit native-hand embodiment. Tool geometry, commands and TCP
belong to the component, while FrankaPandaCfg remains the bare-arm
compatibility selector.
- class embodichain_robots.franka.panda.FrankaPandaCfg#
Legacy FR3 arm selector. The inherited
from_dict()andbuild_pk_serial_chain()use the bare seven-joint arm and flange TCP.