Aloha Mini 2 Pro#
AlohaMiniCfg loads the complete AlohaMini/alohamini2pro.urdf asset without
renaming its joints or assembling separate arms.
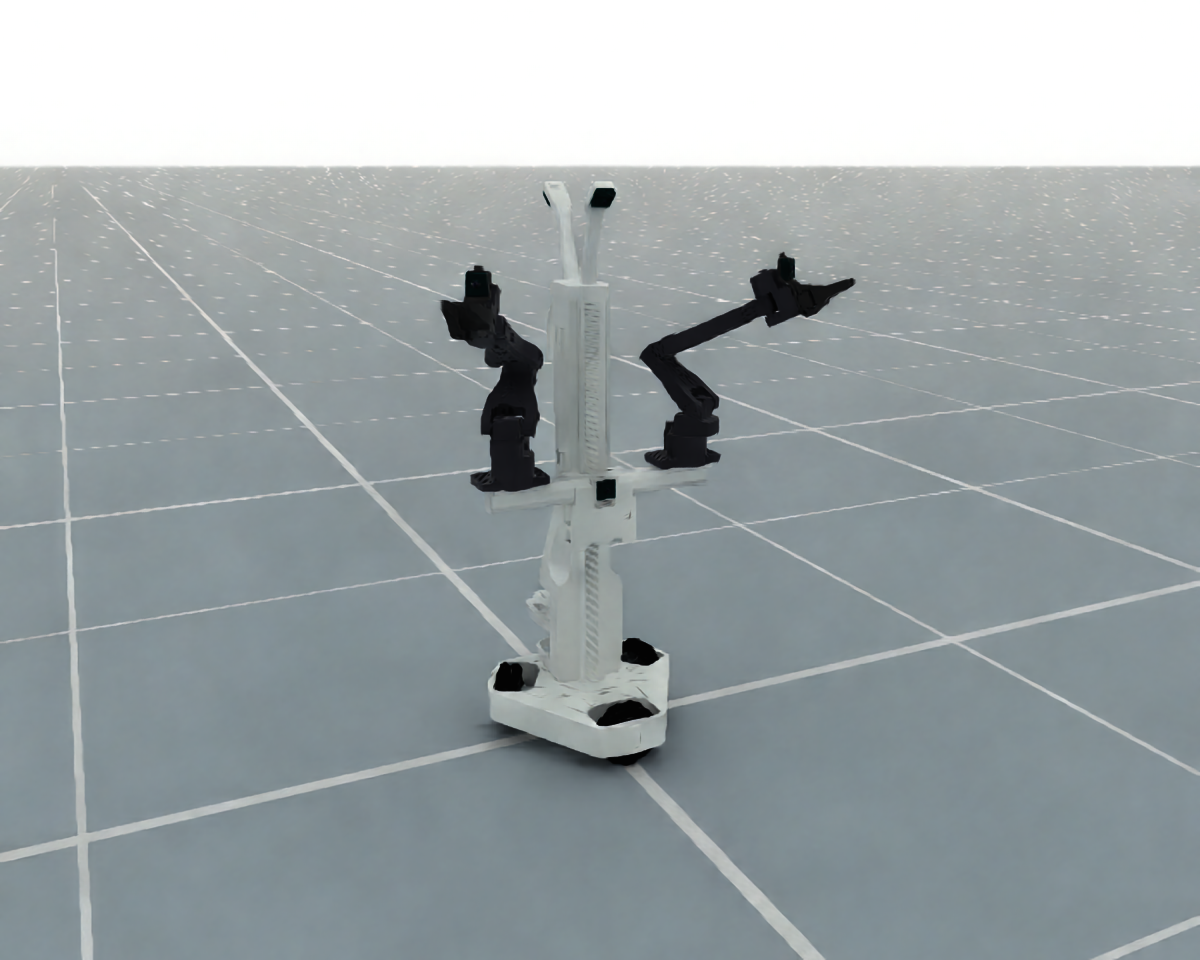
The image uses the registered AlohaMini preset in a display pose, rendered
with RenderCfg(renderer="rt") (OfflineRT). Three soft area lights reveal
the dark arm details while retaining the white body’s surface definition.
Image rendering settings
960 × 1200; 1 sample per pixel; DLSS offscreen reconstruction (quality 2); tone mapping off; exposure 1.0. The default ground and environment emission are supplemented by neutral key, fill and rim rectangular lights. Exact camera, lighting and joint settings are recorded in the render manifest.
from embodichain_robots import AlohaMiniCfg

cfg = AlohaMiniCfg.from_dict({"uid": "aloha_mini"})
robot = sim.add_robot(cfg=cfg)
Control part |
DOF |
Joints / endpoint |
|---|---|---|
|
6 |
Shoulder through wrist; |
|
6 |
Shoulder through wrist; |
|
1 |
|
|
1 |
|
|
1 |
|
The arms use SSIKSolverCfg(backend="warp") on CPU or CUDA with the TCP
frames authored in the asset. The torso retains its position-only
PytorchSolverCfg; the hands use joint-space commands. Explicit solver
replacements remain supported; see the original numerical solver settings.
The source’s three planar base joints and three wheel joints remain outside
these control parts, with position drives that hold their initial positions.
Drive gains follow the CobotMagic simulation preset and can be overridden
through joint_drive_props.
cfg.build_pk_serial_chain() returns all five parts. Each chain is local to
its part: arm poses are relative to left_Base / right_Base, hand poses to
the fixed jaws, and torso poses to base_cad_link. Arm chains do not include
torso or planar base motion. Hand chains describe moving-jaw poses, while the
arm chains describe the grasp TCPs.
Run a headless construction smoke check with:
python -m embodichain_robots.alohamini.aloha_mini.cfg --headless --device cpu
Omit --headless for the interactive simulation window. Select the physics
backend with --physics default or --physics newton.
See the API reference.